SIYI UniFC 6 PICO Technical Dossier: H7 Autopilot Architecture & Industrial Micro Integration
An in-depth technical analysis of the SIYI UniFC 6 PICO micro industrial-grade autopilot. This guide explores its STM32H7 processing core, dual-IMU/barometer hardware redundancy, 100M Ethernet companion computer interface, switchable PWM logic rail, and full integration into open-source ArduPilot and PX4 ecosystems.
Hardware Architecture & Form Factor Innovation
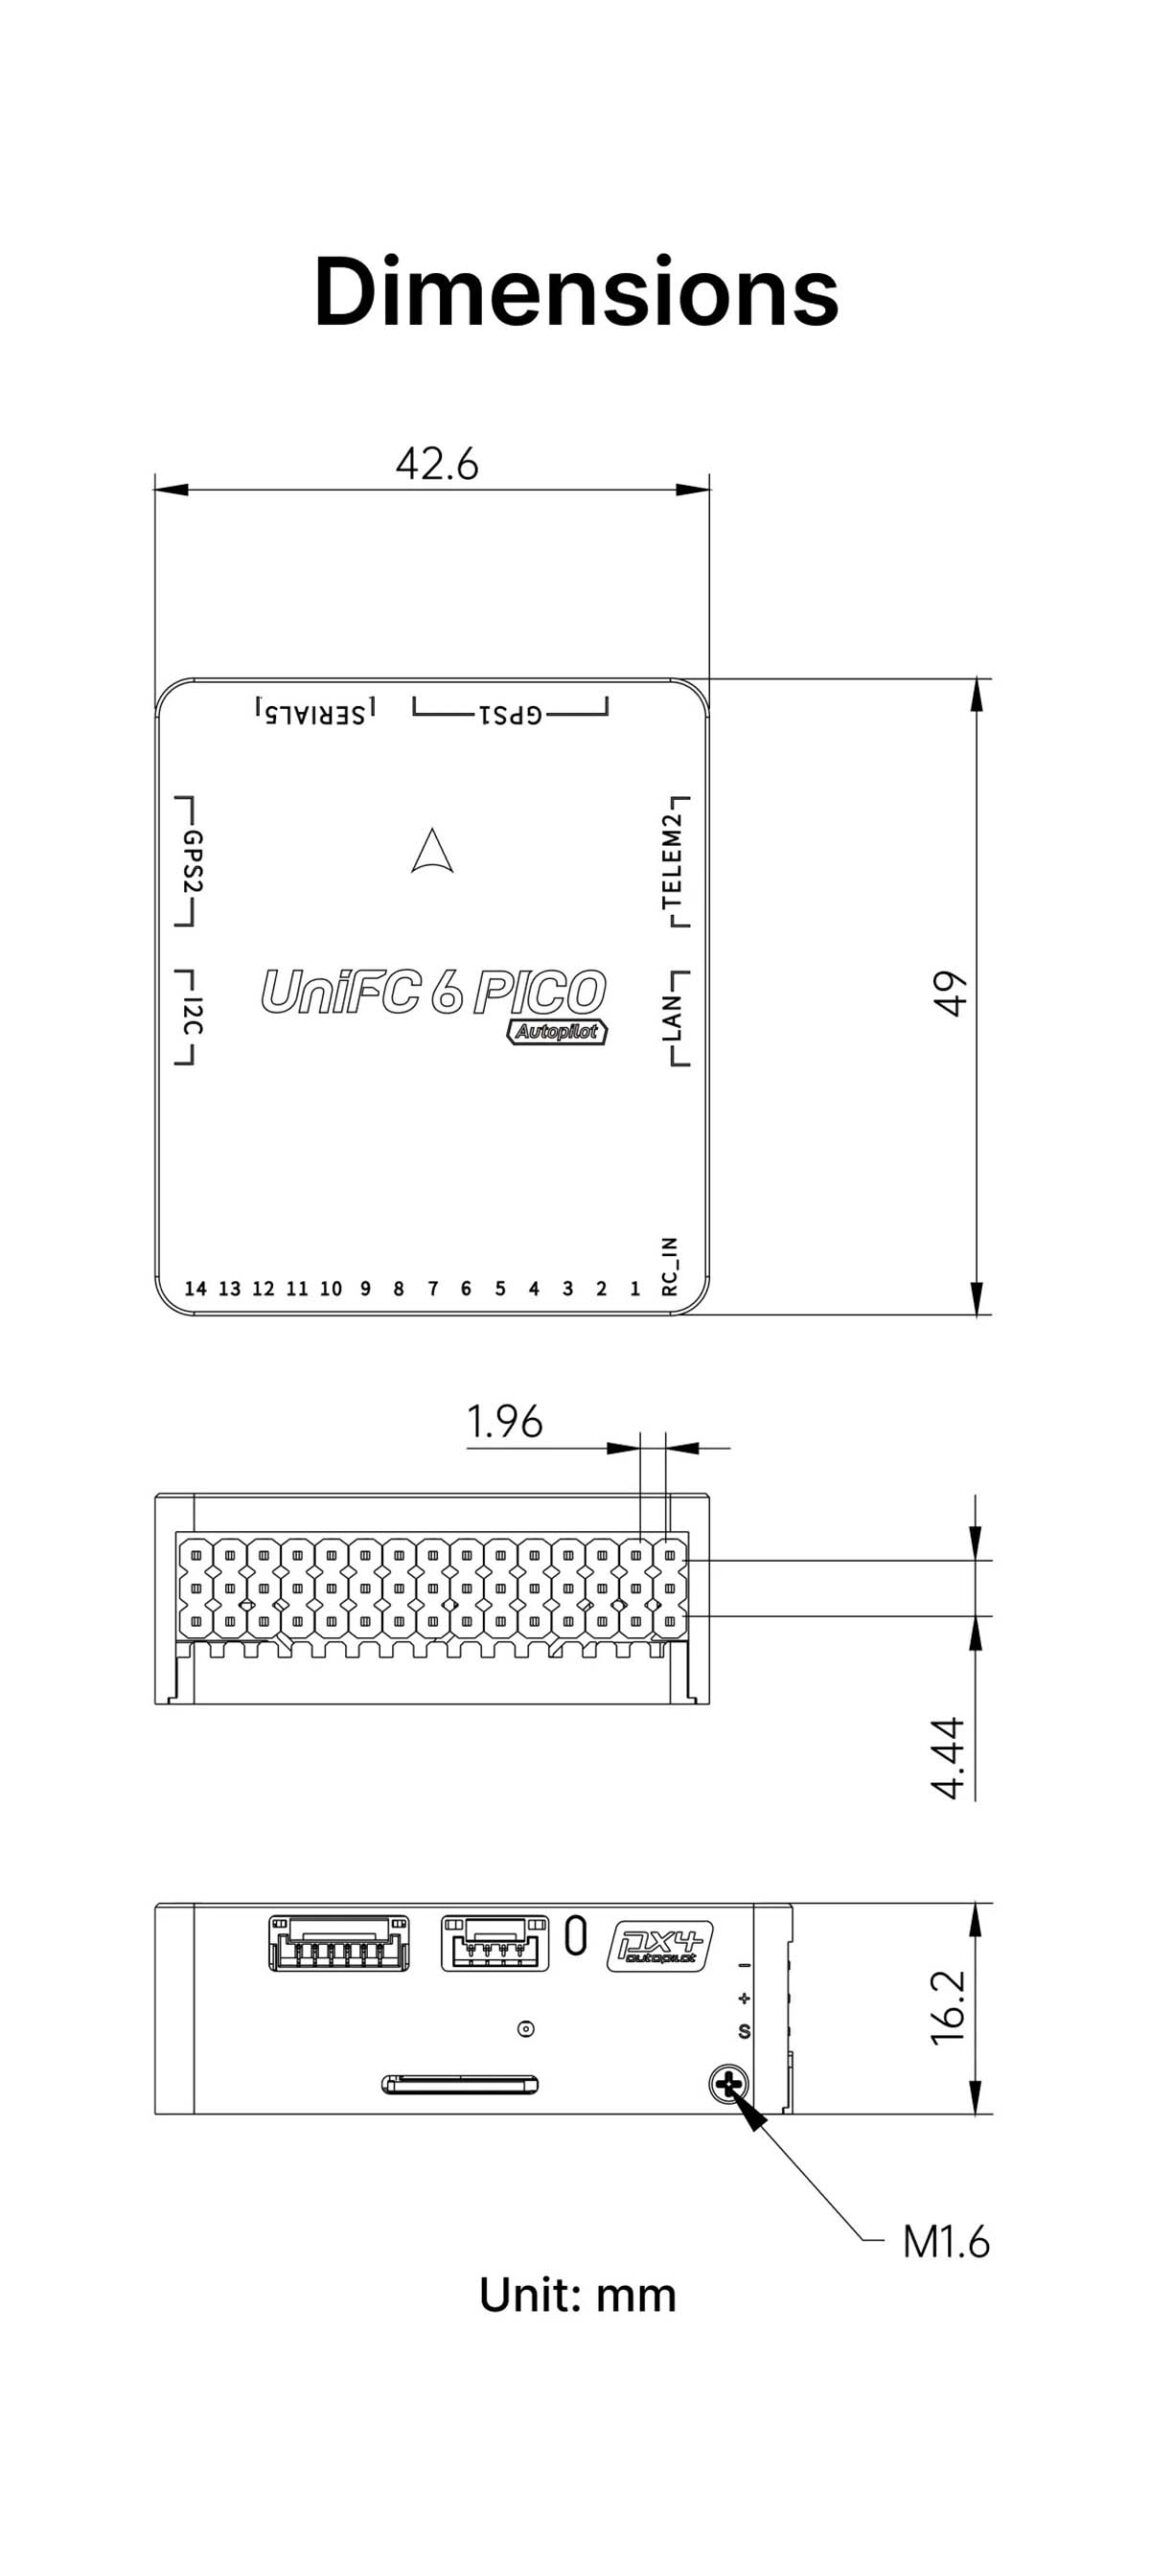
The SIYI UniFC 6 PICO represents a significant shift in open-source industrial flight control hardware. Historically, full multi-sensor redundant Pixhawk-class autopilots were constrained to bulky enclosures weighing 80g to 150g. The UniFC 6 PICO shrinks full industrial-grade hardware into a compact 40g footprint measuring just 49 × 42.6 × 16.2 mm.
- 44% Volume Reduction: Compared to previous-generation SIYI industrial autopilots, the UniFC 6 PICO slashes overall volume by roughly 44% and weight by 30%, enabling high-redundancy ArduPilot/PX4 autonomy on space-constrained platforms like 5-inch to 10-inch FPV drones, micro VTOLs, and lightweight sub-2kg UAVs.
- STM32H7 Processing Core: Powered by an STM32H7 high-performance microcontroller operating at 480 MHz, backed by 2MB Flash memory and 1MB RAM. This processing overhead easily manages complex Extended Kalman Filter (EKF3) state estimations, high-frequency logging, dynamic notch filtering, and real-time obstacle avoidance.
Sensor Redundancy & Thermal Compensation
Redundancy is essential for mission-critical operations. SIYI engineered multi-layered sensor failovers directly into the 40g PICO chassis to prevent single-point inflight failures.
| Subsystem | Hardware Specification | Operational Benefit |
|---|---|---|
| Dual IMU Array | ICM-45686 + BMI088 Redundant Accelerometer / Gyroscope Array | Higher dynamic measurement range and high noise immunity under extreme frame vibration. Automatic real-time failover if one sensor degrades. |
| IMU Thermal Control | Onboard Active Heating Element | Maintains constant sensor die temperature, eliminating gyro zero-bias drift during cold-weather takeoffs or high-altitude operations. |
| Dual Barometer Array | 2× High-Precision Digital Barometric Pressure Sensors | Redundant altitude sensing for stable vertical velocity hold and barometric failover in turbulent air. |
Interface Density, Ethernet, & Switchable PWM Rails
Despite its micro footprint, the UniFC 6 PICO does not sacrifice peripheral connectivity. It features a dense connector array engineered for enterprise payloads and companion computer integration.
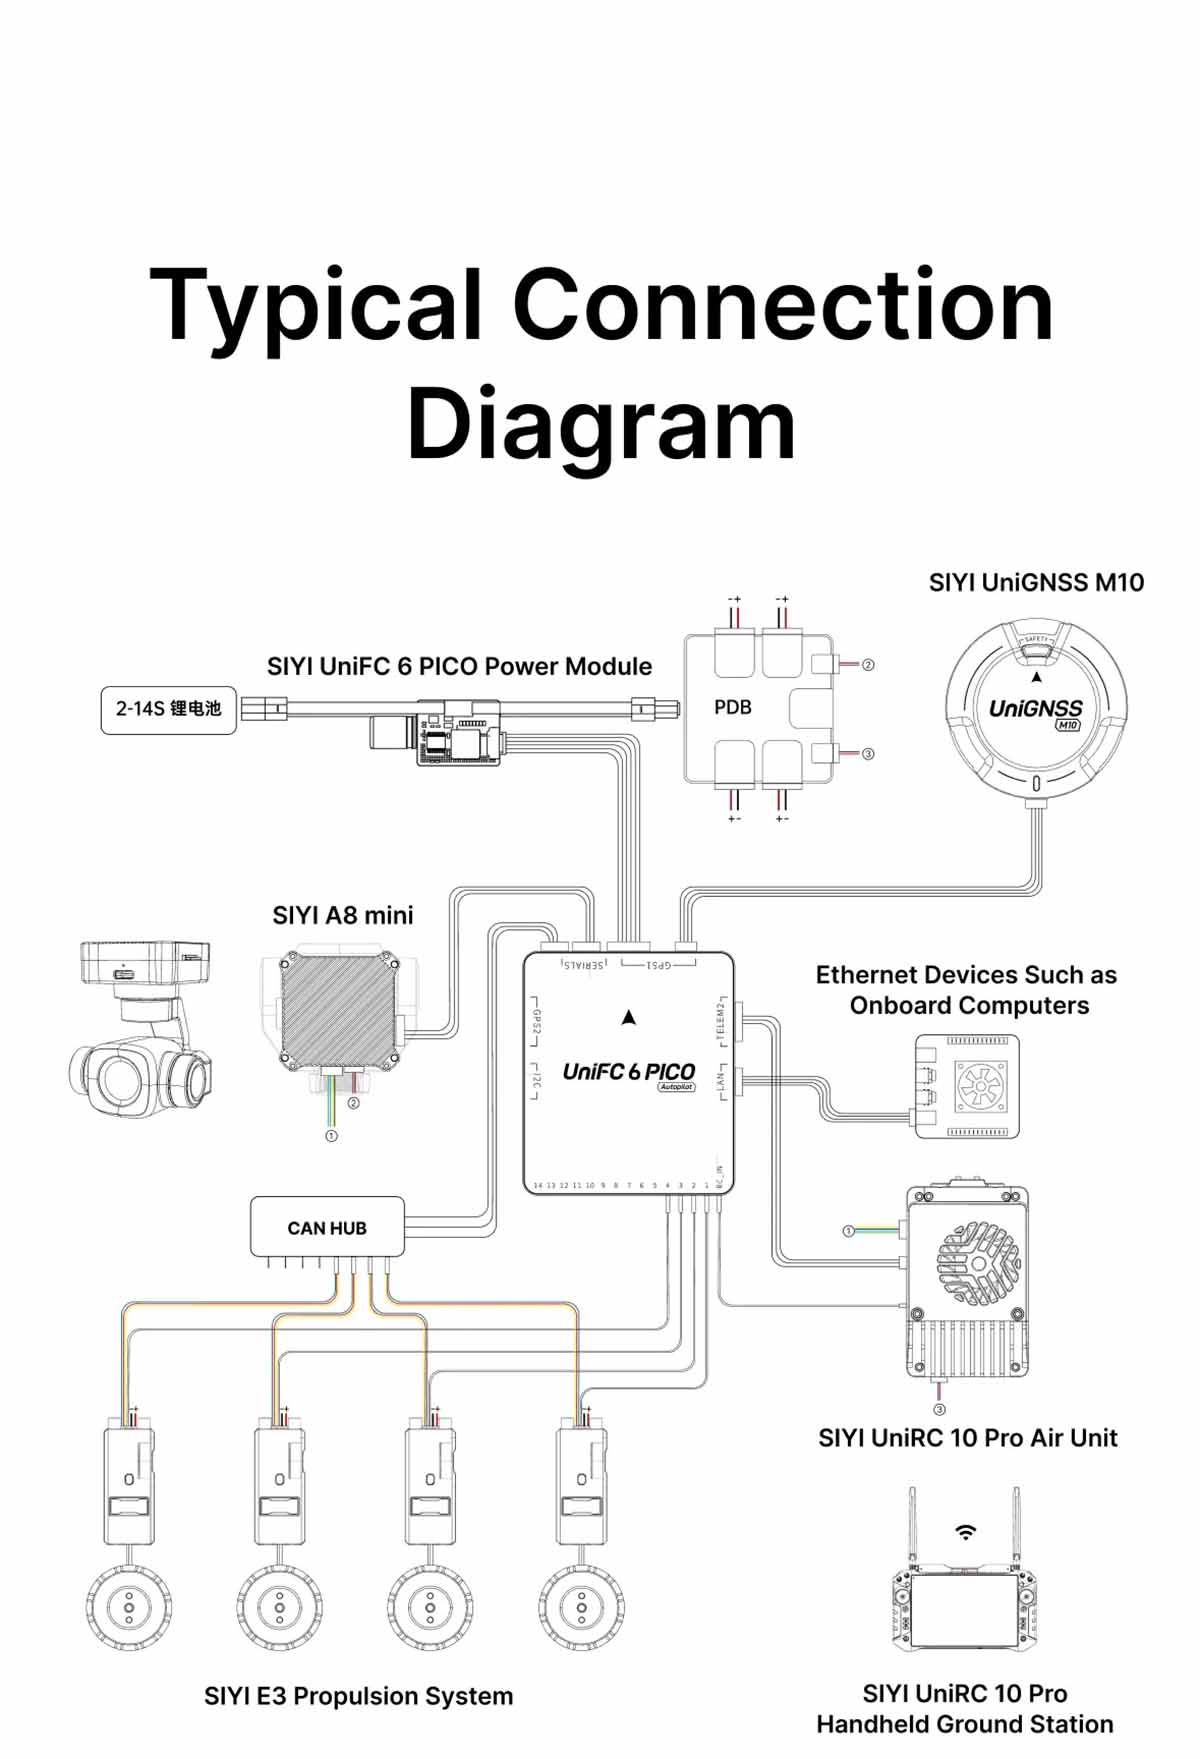
- 100M Ethernet Port: Includes a dedicated 100Mbps Ethernet interface to link directly with onboard companion computers (e.g., Raspberry Pi 5, NVIDIA Jetson Orin Nano) or SIYI smart gimbal cameras. This high-bandwidth pipe enables real-time AI tracking, offboard optical flow navigation, swarm networking, and low-latency RTSP video streaming.
- Comprehensive Serial & Bus Array: Features 5× UART serial ports, 2× CAN bus interfaces (DroneCAN supported), 3× I2C buses, 14× PWM output channels, 1× RC Input (SBUS/PPM), 1× Type-C USB, 1× TF/MicroSD card slot for high-rate data logging, and 1× Power Module (PM) input.
Ecosystem & Firmware Compatibility
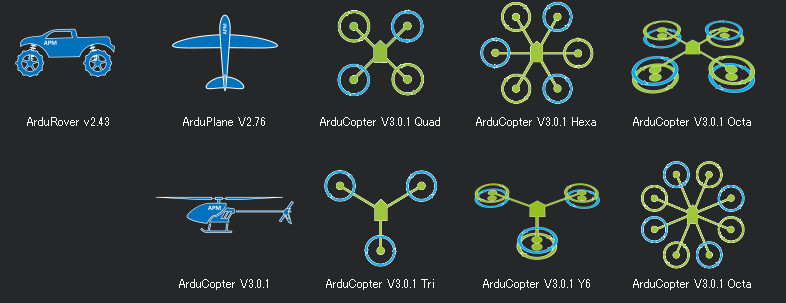
The UniFC 6 PICO is fully compatible with open-source ArduPilot and PX4 Autopilot stacks. It supports a wide range of vehicle configurations out of the box:
- Multi-Vehicle Support: Multirotors (quad, hexa, octa), Fixed-Wing, Hybrid VTOL, High-Performance Helicopters, FPV Free-Flight, Unmanned Ground Vehicles (UGV), and Unmanned Surface Vessels (USV).
- SIYI Enterprise Integration: Native plug-and-play compatibility with the SIYI UniGNSS M10 GPS, UniASP L10D Airspeed sensors, F9P RTK positioning modules, Hall-effect power modules, and UniRC / MK32 ground control stations.
- UniGCS Support: Configurable via standard Mission Planner / QGroundControl, or through SIYI’s unified UniGCS suite for integrated payload, video, and autopilot telemetry setup.
References & Documentation
Official product overview, hardware specifications, and peripheral mapping guides from SIYI Technology.
Official PX4 developer documentation detailing pinouts, sensor orientation, and target build configurations for the UniFC 6 PICO hardware.
Official documentation for configuring enterprise UAVs, VTOL platforms, and rovers on STM32H7-based hardware platforms.